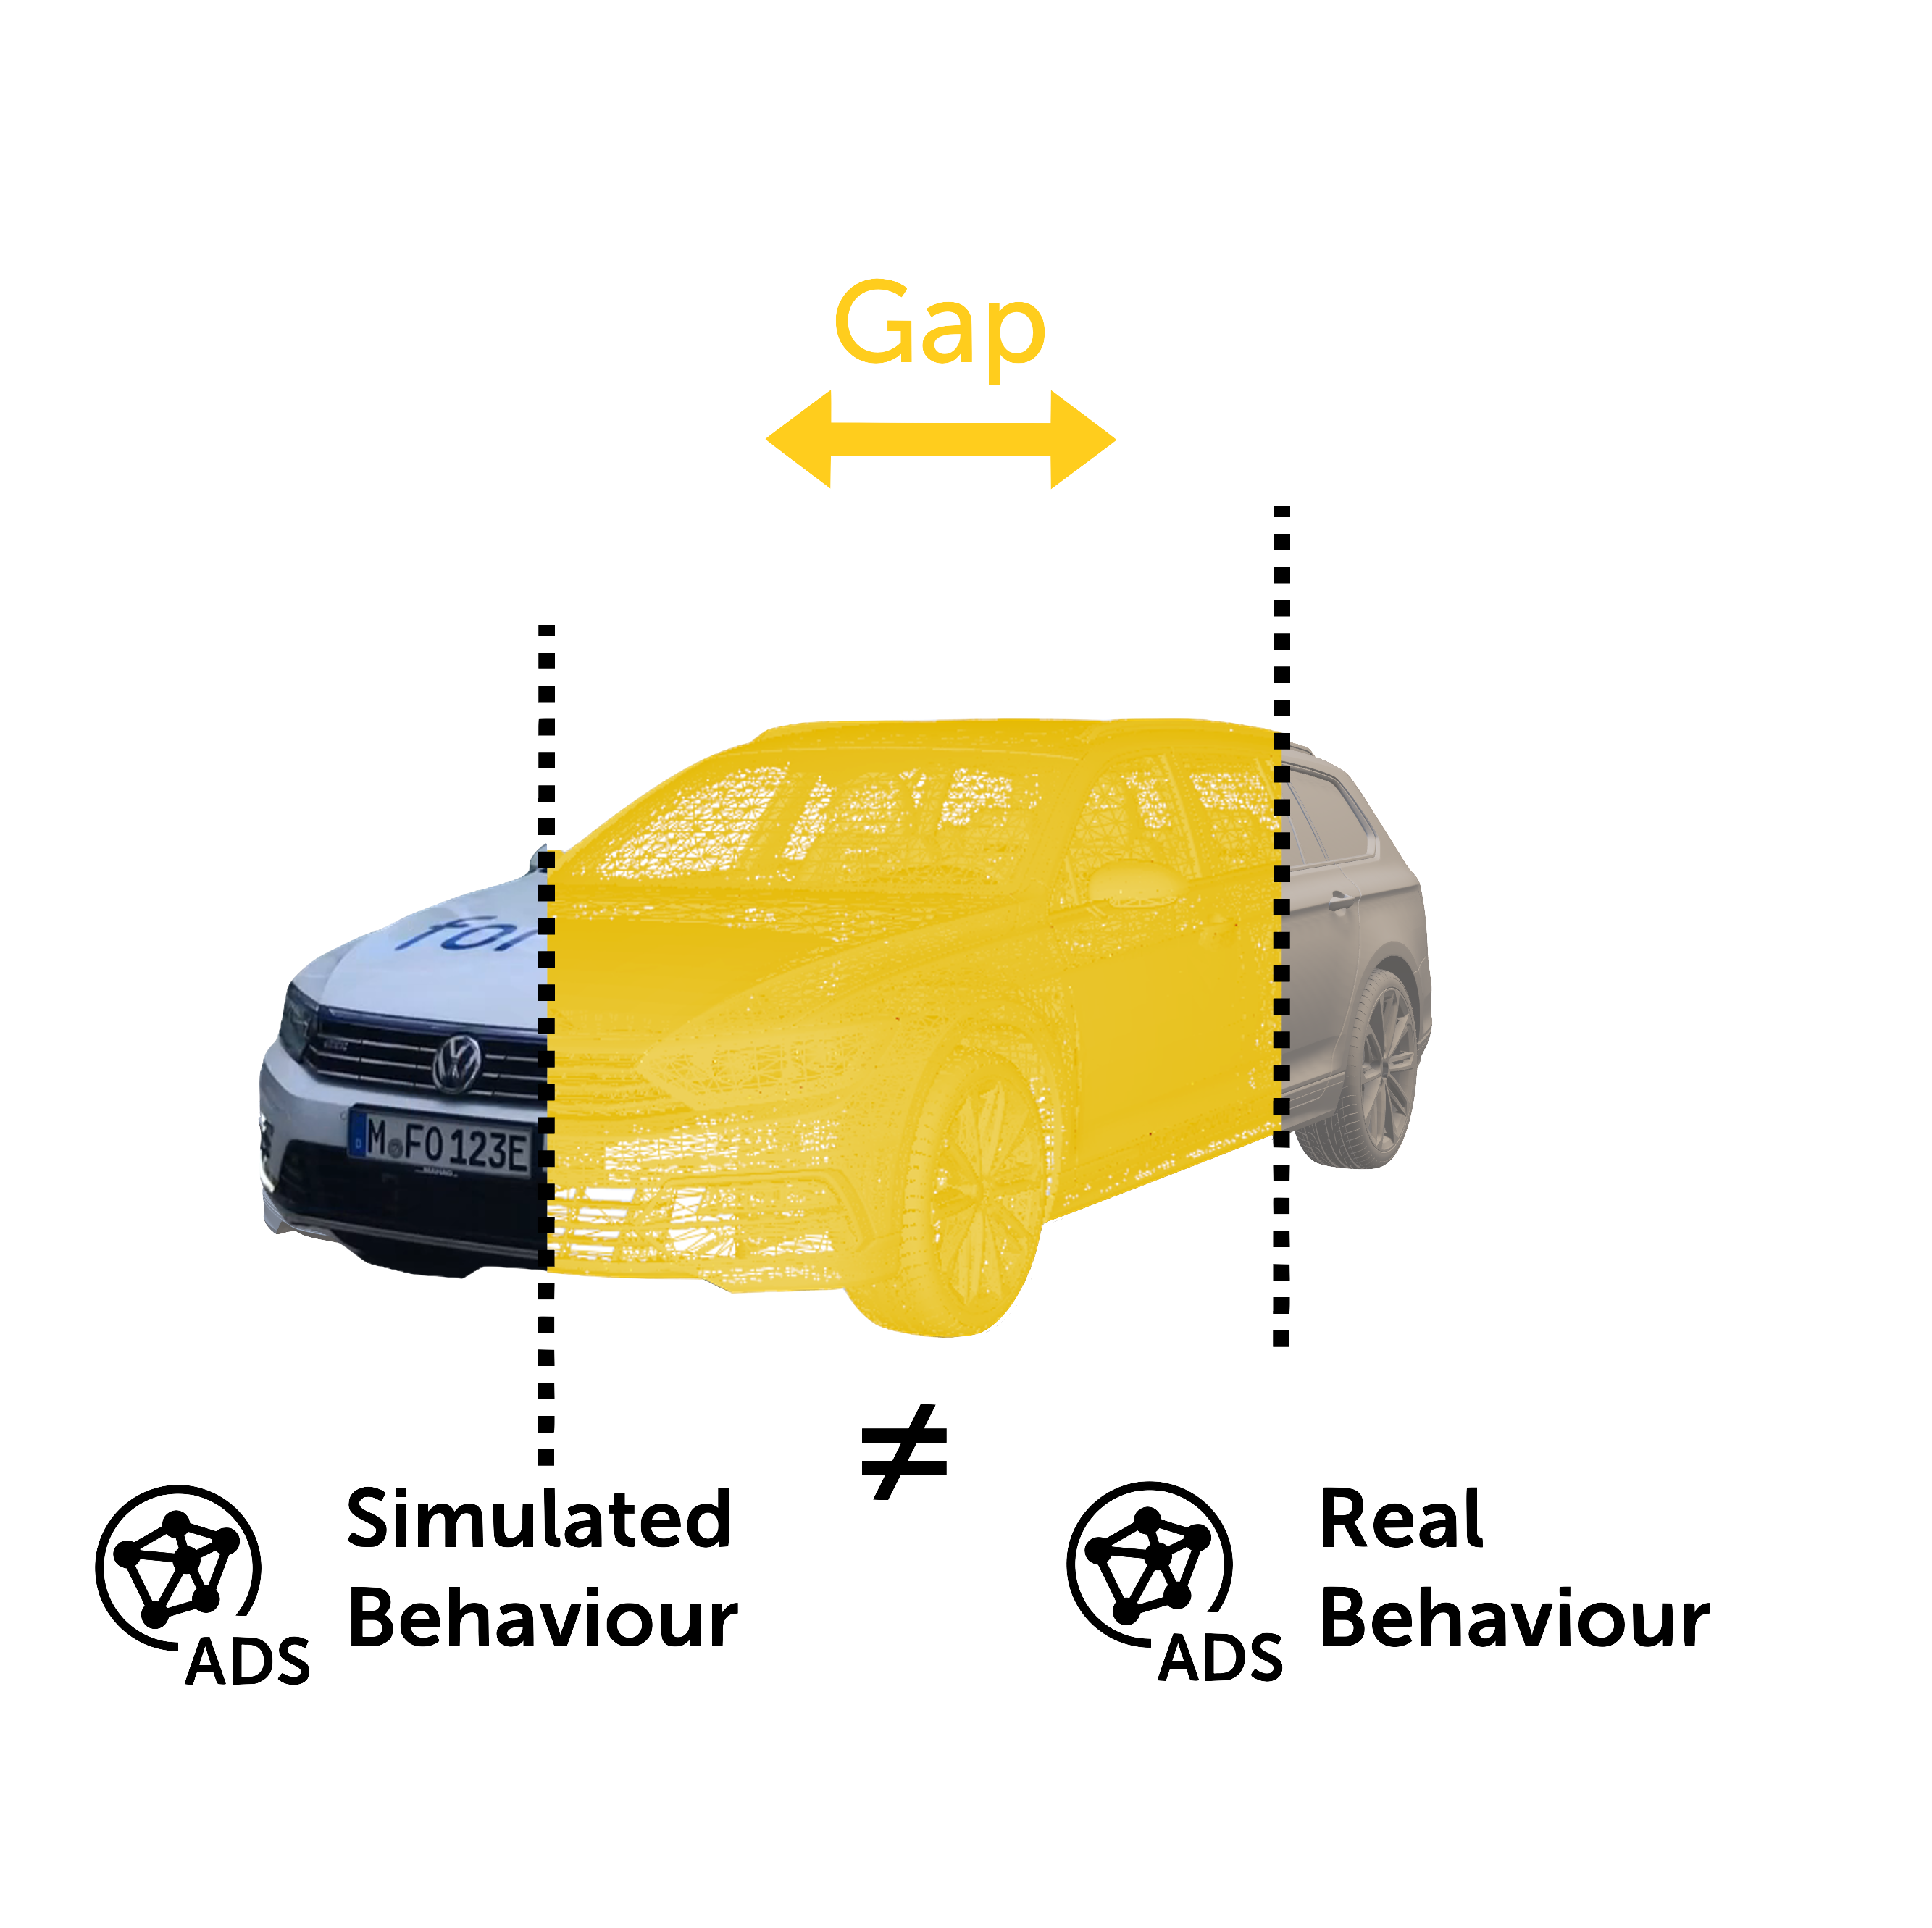
The reality gap
Research.
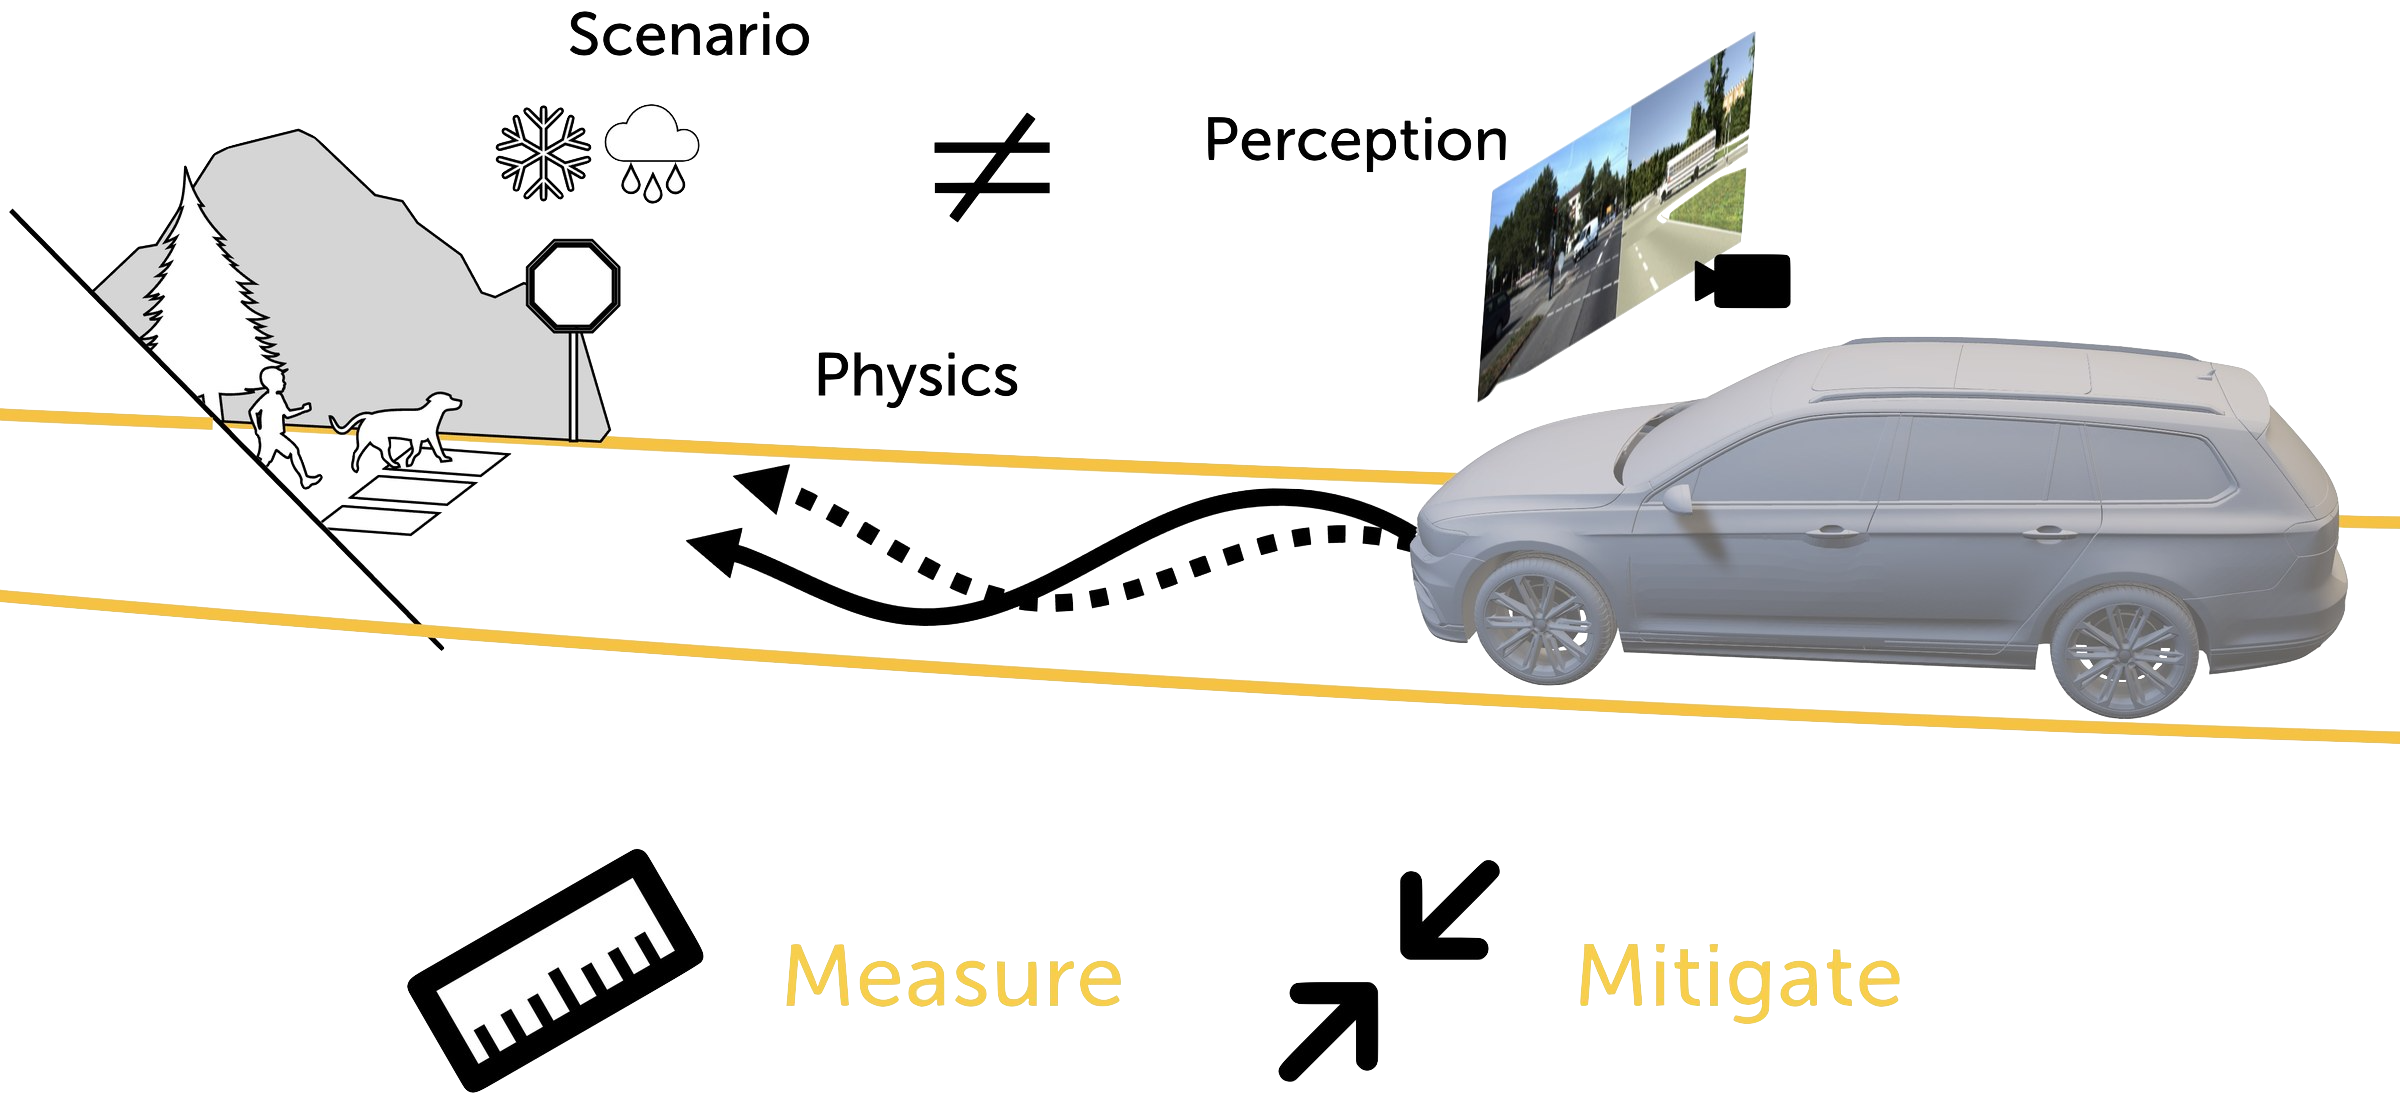
How well results transfer between simulation and the real world, how to make a system more robust once that gap is measured, and how to reuse real driving data to make simulation more realistic.
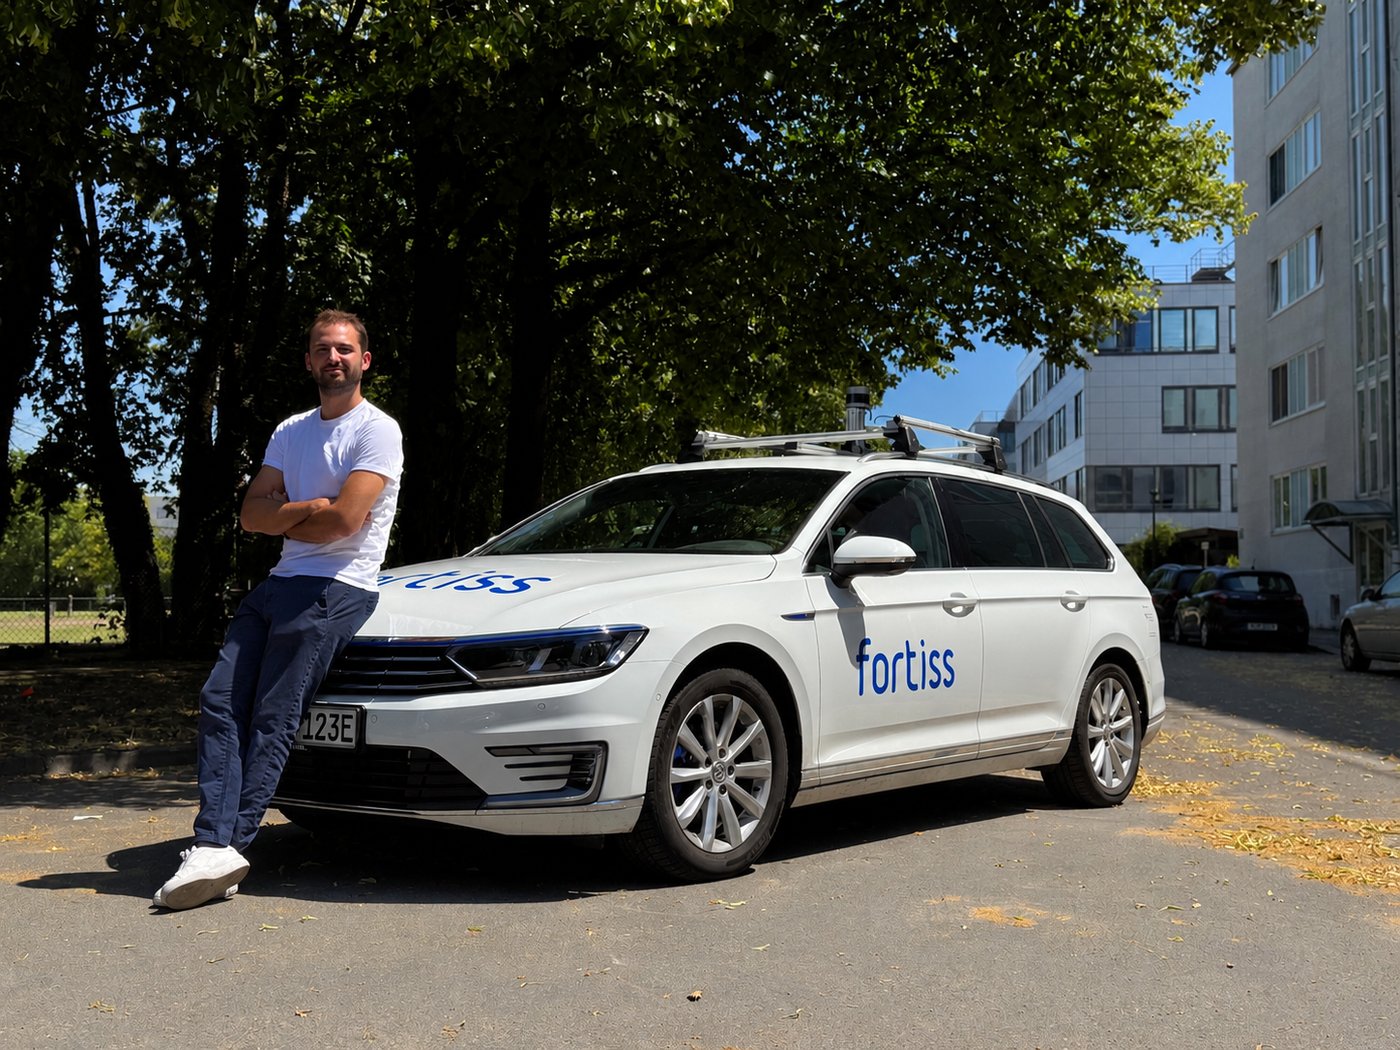
fortiss · Technical University of Munich
I like taking systems apart to see why they break, then putting them back together better. Fortuna, the research vehicle on the right, is the biggest thing I have taken apart so far.
Researcher at fortiss, doctoral candidate at TUM, and technical lead for Fortuna, our autonomous-driving research vehicle.
The reality gap
How well results transfer between simulation and the real world, how to make a system more robust once that gap is measured, and how to reuse real driving data to make simulation more realistic.
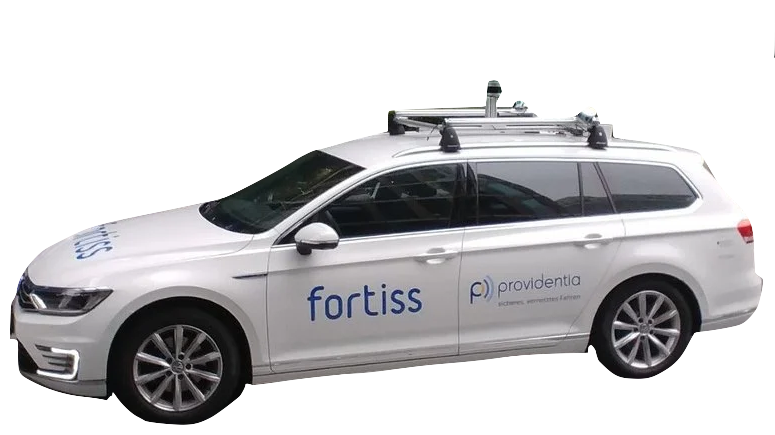
The research platform
A full-size, street-legal Volkswagen Passat used for camera- and LiDAR-based autonomous-driving research, which I brought back into operation after a period of inactivity.
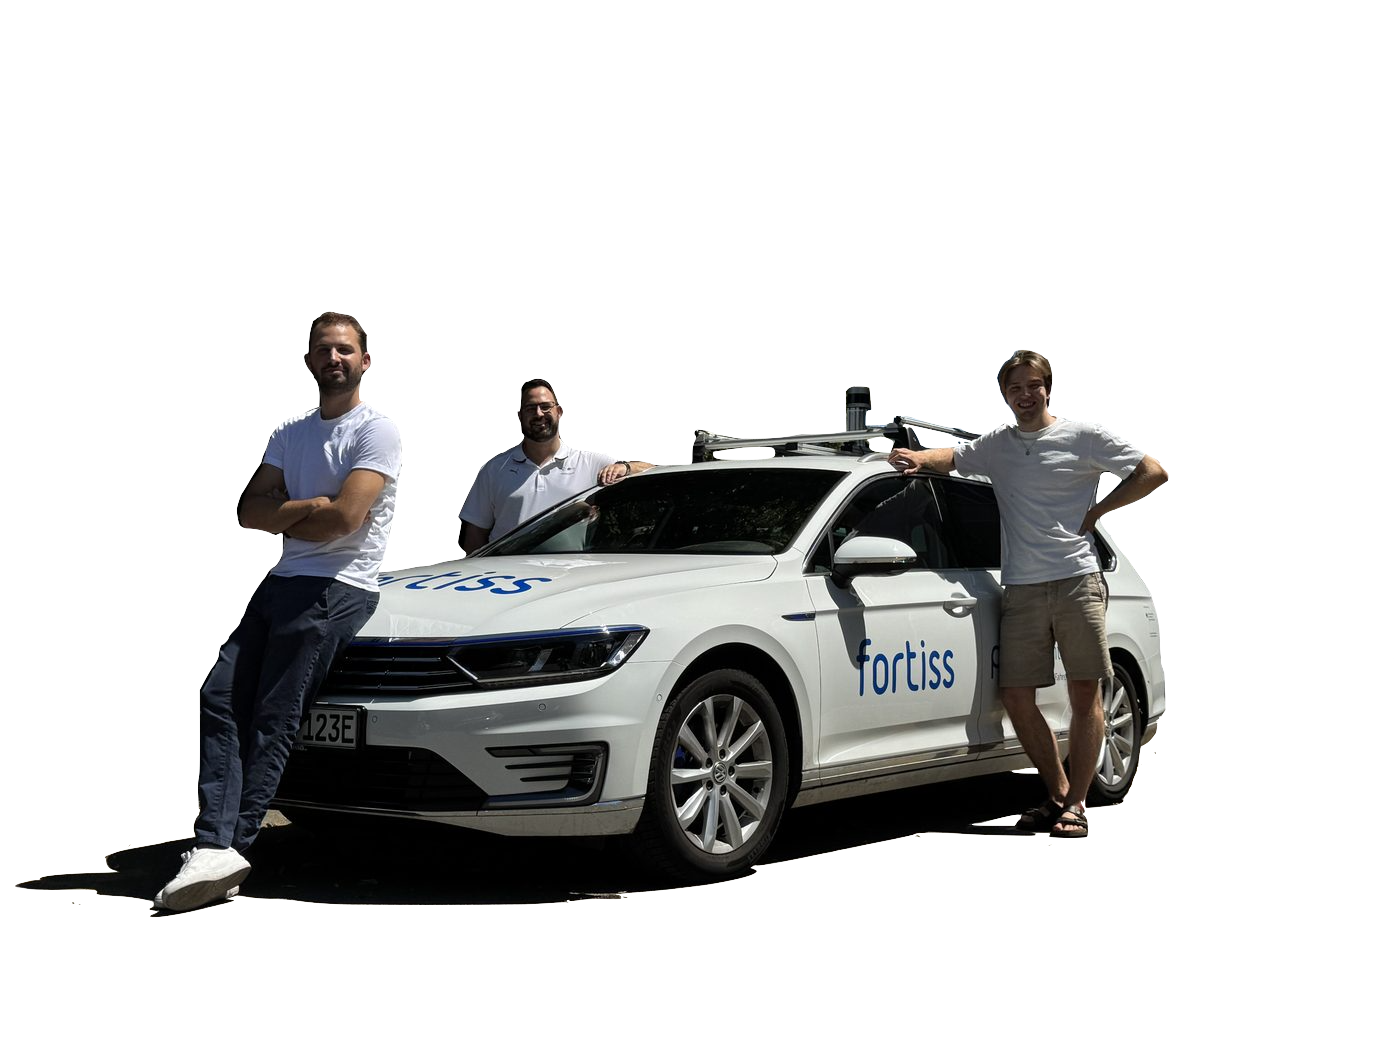
Students and courses
A practicum course on testing autonomous-driving systems, and the student projects I have supervised or co-supervised around it.
Selected work
Peer-reviewed papers, executable tools, and replication packages.
The longer version
Where I grew up, how I ended up here, and what I do outside research.
Just for fun
I scanned Fortuna into a 3D model. Take it for a spin, no research question required.